
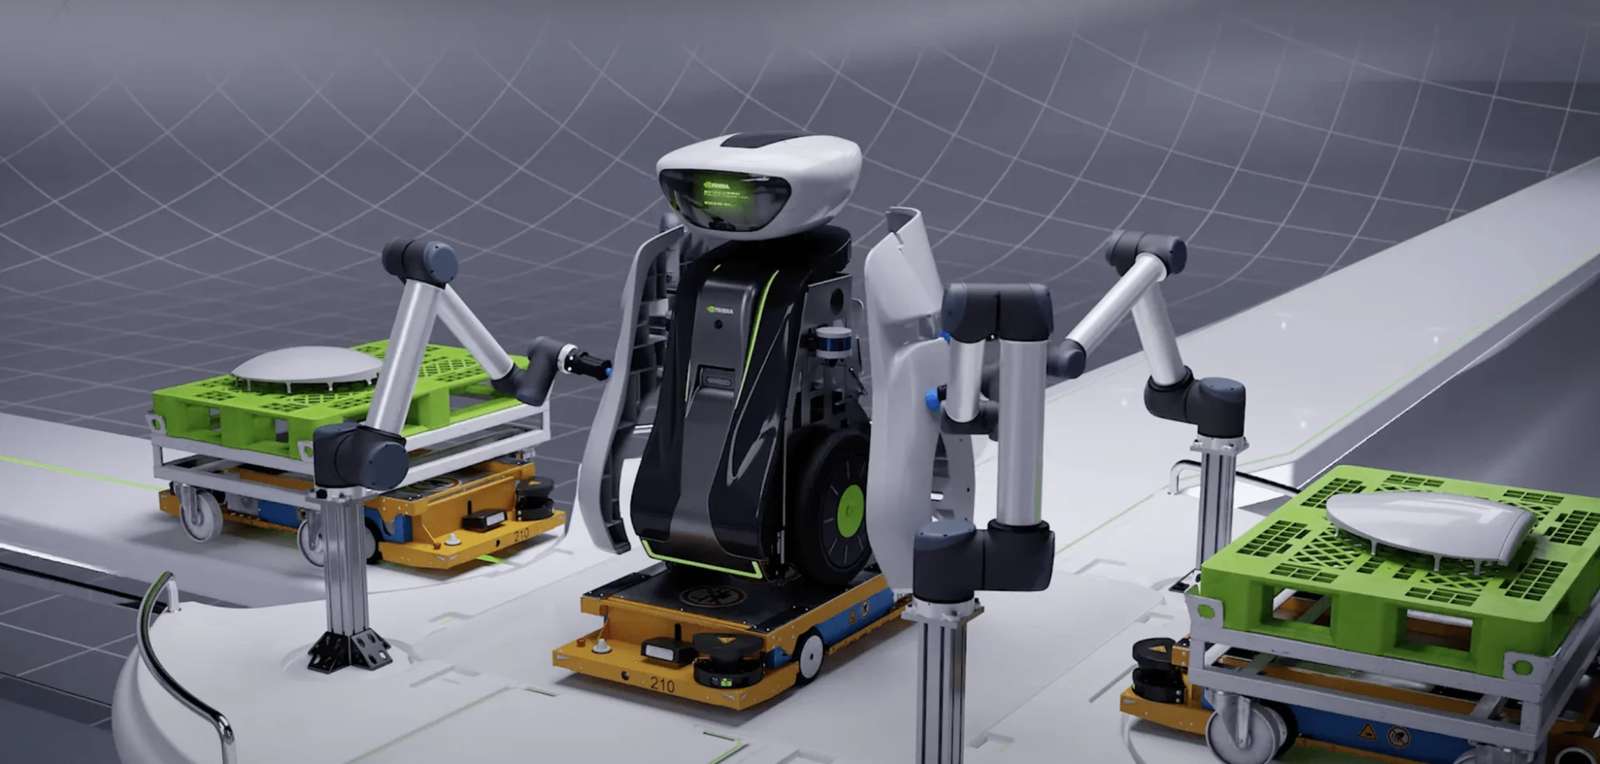
NVIDIA recently announced its latest initiatives to deliver a suite of perception technologies for the Robotic Working System (ROS) developer community. In addition, the company announced that its developer toolbox for supporting AI-powered robotics, Isaac, will deepen assistance for the ROS.
NVIDIA says that these initiatives will reduce development time and improve performance for developers seeking to incorporate cutting-edge computer vision and AI/ML functionality into their ROS-based robotics applications.
The announcement was made at the recently held ROS World 2021, a convention for builders, engineers, and hobbyists who work on ROS, a well-liked open-source framework that helps builders construct and reuse code used for robotics purposes.
NVIDIA also agreed with Open Robotics to accelerate ROS 2’s performance on NVIDIA’s Jetson edge AI platform and GPU-based systems to enable seamless simulation interoperability between Open Robotics’s Ignition Gazebo and NVIDIA Isaac Sim on Omniverse.

The latest release of Isaac Sim includes significant support for the ROS developer community. Some of the more compelling examples of this are the ROS2 Navigation stack and the MoveIt Motion Planning Framework.
Hardware-accelerated packages known as Isaac GEMs for ROS were also released, which will make it easier for ROS developers to build high-performance solutions on the Jetson platform. The purpose of the newly launched Isaac ROS GEM for Stereo Visual Odometry is to help autonomous vehicles keep track of where a camera is relative to its initial position. With this solution, ROS developers will get a real-time (>60fps@720p) stereo camera visual odometry solution that runs immensely fast and can run HD resolution in real-time on a Jetson Xavier AGX.

With DNN Inference GEM, ROS builders can now leverage any of NVIDIA’s inference fashions accessible on NGC or can provide their very own DNN. TensorRT, or Triton, NVIDIA’s inference servers, will deploy these optimized packages.
Scheduled to be launched in November 2021, this GA launch of Isaac SIM will include enhancements within the UI and efficiency, making simulation-building a lot quicker. The ROS bridge will enhance, and so will the developer expertise with an elevated variety of ROS samples. The brand new artificial knowledge workflow that comes with the Isaac Sim helps construct manufacturing high-quality datasets, addressing the protection and high-quality issues of autonomous robots.
- OpenAI Signs Four Agreements With Abu Dhabi Across Government, Energy And Investment
- Deep-Tech and Green Finance to Drive India’s Climate Investments in 2027
- Google’s Project Suncatcher Satellite Generates First AI Response in Orbit
- DeepSeek Proposes Super-Agent Architecture to Automate AI Coding Workflows
- Arrowhead AI Launches Fletch Voice Model for Multilingual Customer Calls
- Amazon Warns Engineers Against AI Productivity Traps in Latest Memo